Robotics & computer vision · 2023–2024
ARJUNA hexapod robot
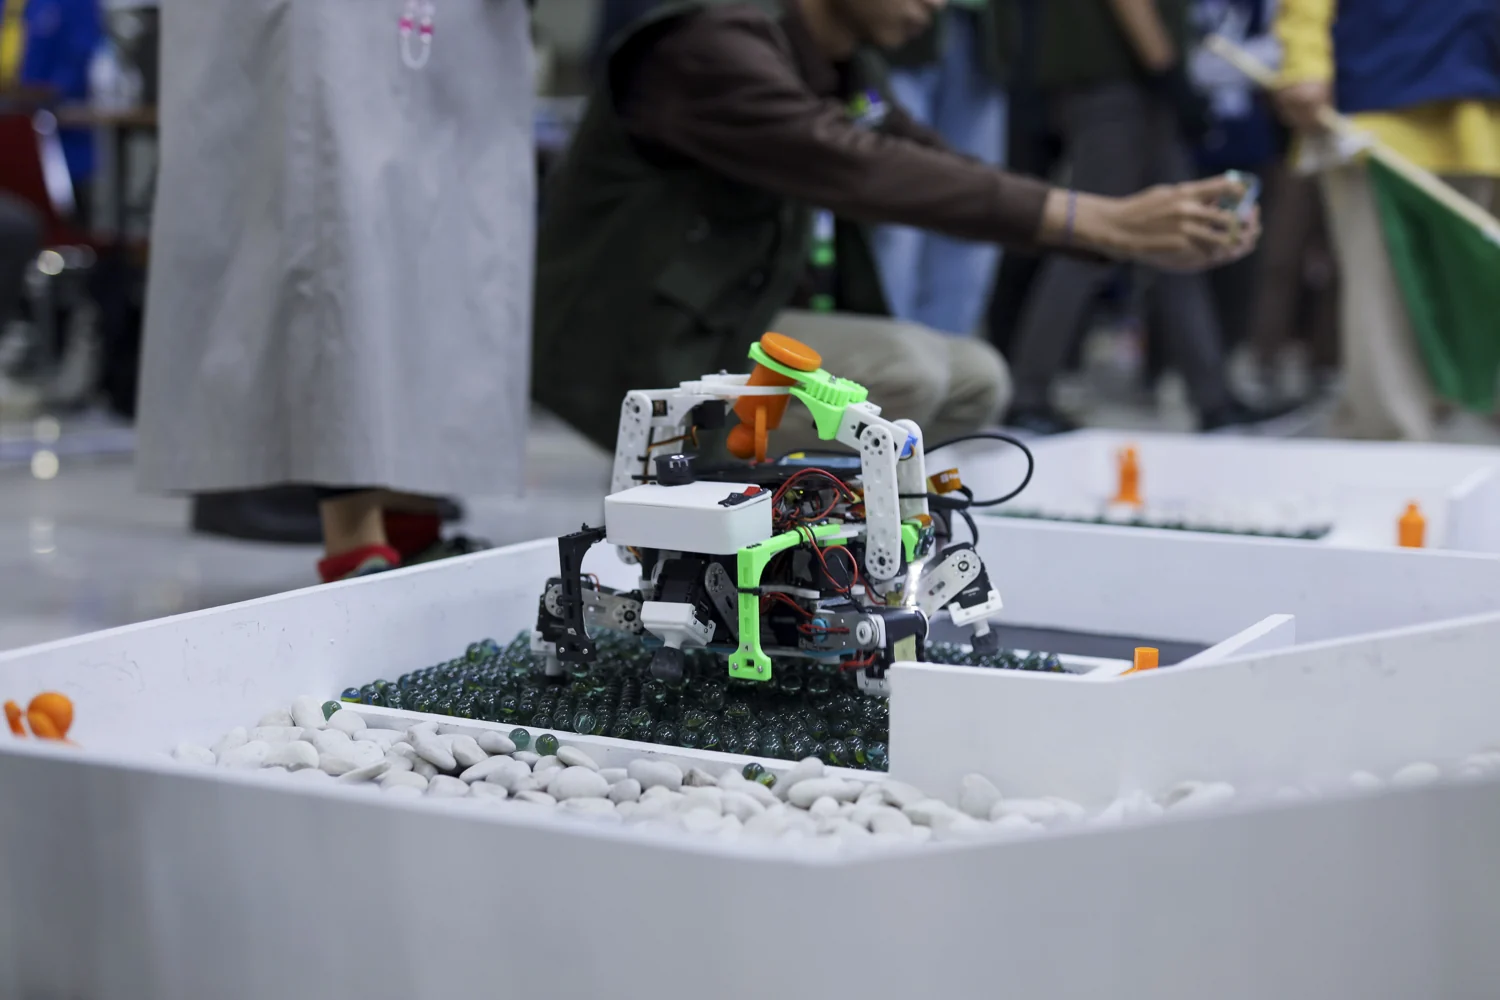
A six-legged robot project combining automatic balance and real-time object detection for the Kontes Robot Indonesia.
Project scope
The project covered a six-legged robot with automatic IMU-based balance and real-time YOLOv8 object detection for autonomous navigation.
My role
I led Team ARJUNA. The project combined a six-legged platform, automatic balance, perception, and the integration needed for the competition.
Outcome
Team ARJUNA became a finalist in the 2024 Kontes Robot Indonesia, Kontes Robot SAR Indonesia division.